Robotic manipulation, robotic materials, and full-stack humanoids
What we work on
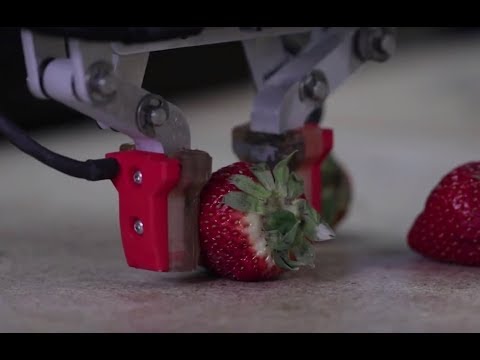
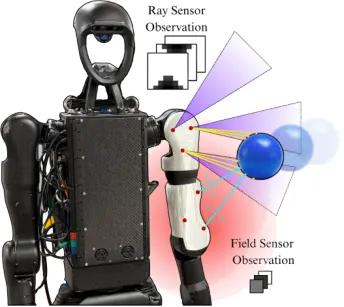
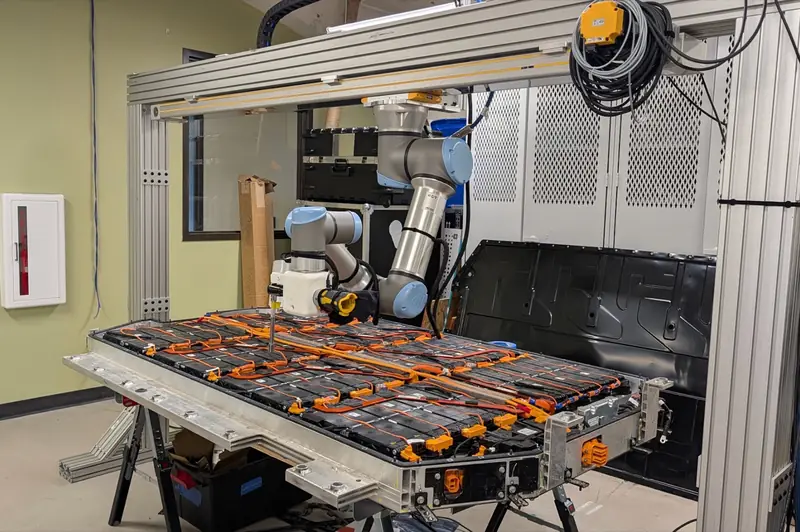
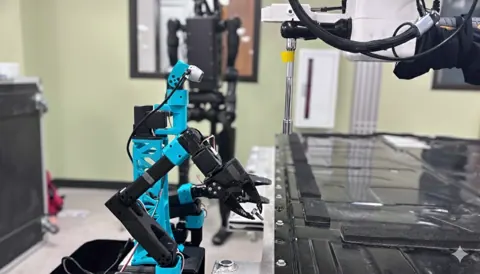
We investigate robotic manipulation, to give robots human-like object manipulation skills, and robotic materials — composite materials that embed sensing, actuation, computation and communication, such as robotic muscles, skin and bones. The two strands now come together in full-stack humanoid development.
Our alumni have become tenure-track professors at R1 universities, graduate students and post-docs at the world's premier research universities, and engineers and scientists at leading companies.
Research areas
-
Robotic manipulation
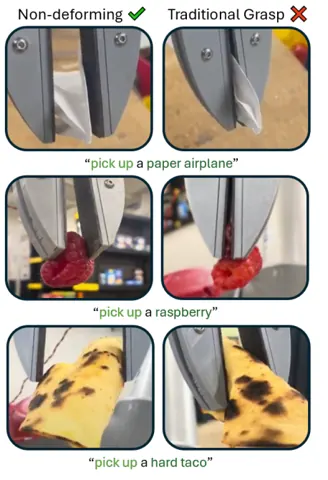
Giving robots human-like object manipulation skills through perception, learning and force-aware control.
-
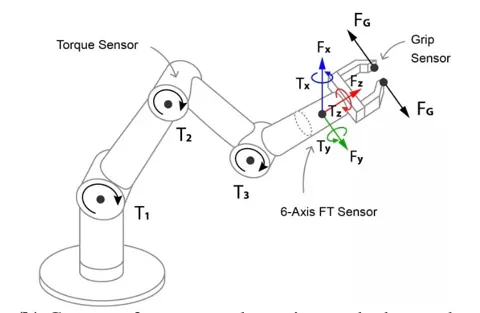
Robotic materials
Composite materials that embed sensing, actuation, computation and communication — robotic muscles, skin and bones.
-
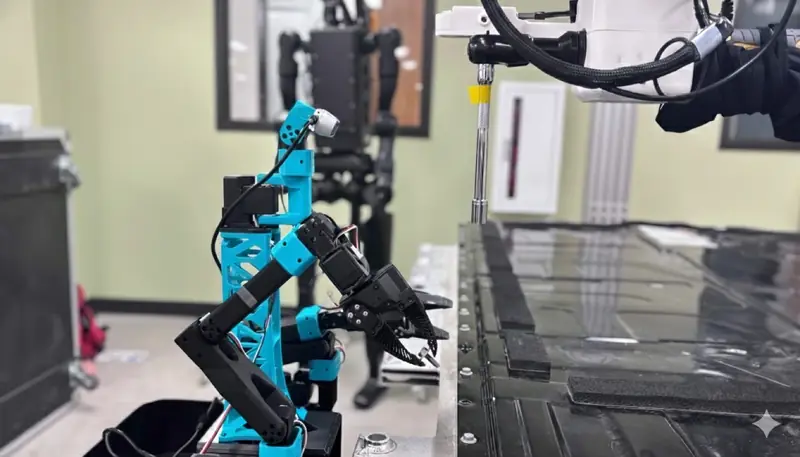
Full-stack humanoids
Bringing manipulation and robotic materials together toward capable, general-purpose humanoid systems.
Recent publications
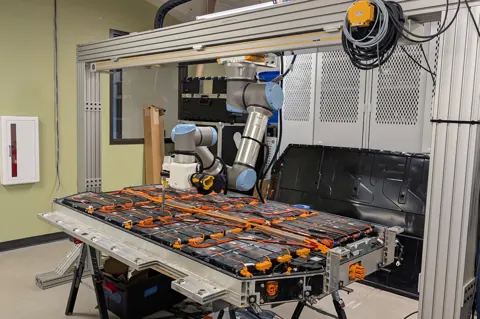
Videos
-
IEEE Robotics & Automation Society
-
Associated Press
-
TechCrunch