• Skip to content
  • Skip to navigation
University of Notre Dame

Correll Laboratory

Aerospace and Mechanical Engineering

  • Home
  • Publications
  • People
  • Teaching
  • Art
  • Home
  • Publications
  • People
  • Teaching
  • Art
  1. Home
  2. Publications

Publications

158 publications across 22 years, synchronised weekly from OpenAlex.

  • 2026
  • 2025
  • 2024
  • 2023
  • 2022
  • 2021
  • 2020
  • 2019
  • 2018
  • 2017
  • 2016
  • 2015
  • 2014
  • 2013
  • 2012
  • 2011
  • 2010
  • 2009
  • 2008
  • 2007
  • 2006
  • 2002

2026 6 publications

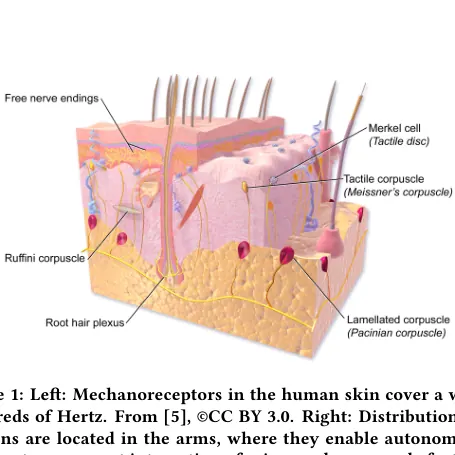
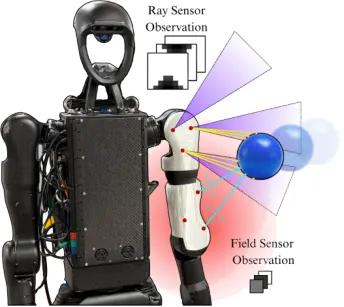
  • Figure from the paper “Egocentric Tactile and Proximity Sensors as Observation Priors for Humanoid Collision Avoidance”

    Egocentric Tactile and Proximity Sensors as Observation Priors for Humanoid Collision Avoidance

    Carson Kohlbrenner, Niraj Pudasaini, William Xie, Naren Sivagnanadasan, Nikolaus Correll, Alessandro Roncone

    arXiv (Cornell University) · 2026

  • First page of the paper “Liquid Networks with Mixture Density Heads for Efficient Imitation Learning”

    Liquid Networks with Mixture Density Heads for Efficient Imitation Learning

    Nikolaus Correll

    arXiv (Cornell University) · 2026

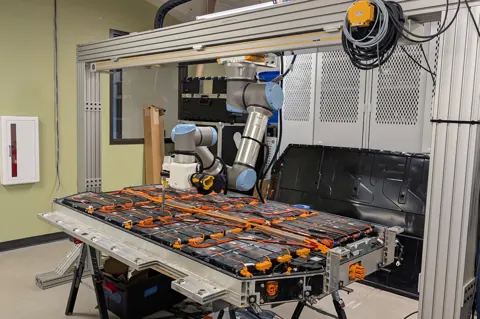
  • Figure from the paper “Robotic Agentic Platform for Intelligent Electric Vehicle Disassembly”

    Robotic Agentic Platform for Intelligent Electric Vehicle Disassembly

    Zachary Allen, Max Conway, Lyle Antieau, Allen Ponraj, Nikolaus Correll

    arXiv (Cornell University) · 2026

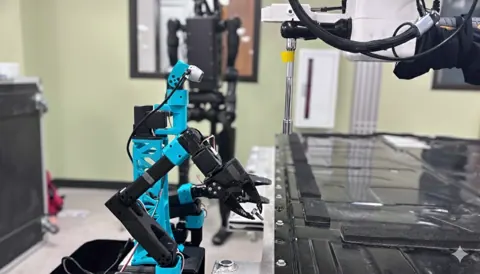
  • Figure from the paper “Cutting the Cord: System Architecture for Low-Cost, GPU-Accelerated Bimanual Mobile Manipulation”

    Cutting the Cord: System Architecture for Low-Cost, GPU-Accelerated Bimanual Mobile Manipulation

    Artemis Shaw, Chen Liu, Justin Costa, Rane Gray, Alina Skowronek, Kevin Diaz, Nam Bui, Nikolaus Correll

    arXiv (Cornell University) · 2026

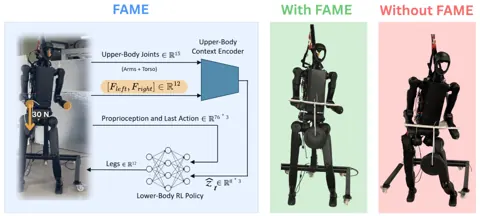
  • Figure from the paper “FAME: Force-Adaptive RL for Expanding the Manipulation Envelope of a Full-Scale Humanoid”

    FAME: Force-Adaptive RL for Expanding the Manipulation Envelope of a Full-Scale Humanoid

    Niraj Pudasaini, Yutong Zhang, Jensen Lavering, Alessandro Roncone, Nikolaus Correll

    arXiv (Cornell University) · 2026

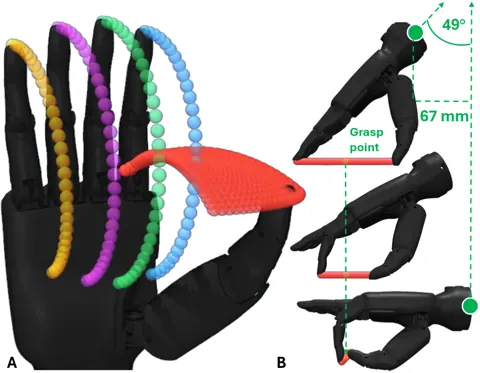
  • Figure from the paper “Characterization, Analytical Planning, and Hybrid Force Control for the Inspire RH56DFX Hand”

    Characterization, Analytical Planning, and Hybrid Force Control for the Inspire RH56DFX Hand

    Xuan Tan, William Xie, Nikolaus Correll

    arXiv (Cornell University) · 2026

2025 3 publications

  • Figure from the paper “On the Dual-Use Dilemma in Physical Reasoning and Force”

    On the Dual-Use Dilemma in Physical Reasoning and Force

    William Xie, Enora Rice, Nikolaus Correll

    arXiv (Cornell University) · 2025

  • Figure from the paper “Unfettered Forceful Skill Acquisition with Physical Reasoning and Coordinate Frame Labeling”

    Unfettered Forceful Skill Acquisition with Physical Reasoning and Coordinate Frame Labeling

    William Xie, Conway, Max, Yutong Zhang, Nikolaus Correll

    arXiv (Cornell University) · 2025

  • Figure from the paper “Towards Forceful Robotic Foundation Models: a Literature Survey”

    Towards Forceful Robotic Foundation Models: a Literature Survey

    William Xie, Nikolaus Correll

    arXiv (Cornell University) · 2025

2024 5 publications

  • Figure from the paper “A Machine Learning Approach to Contact Localization in Variable Density Three-Dimensional Tactile Artificial Skin”

    A Machine Learning Approach to Contact Localization in Variable Density Three-Dimensional Tactile Artificial Skin

    Carson Kohlbrenner, Murray, Mitchell, Yutong Zhang, Caleb Escobedo, Thomas Dunnington, Nicholas Stevenson, Nikolaus Correll, Alessandro Roncone

    arXiv (Cornell University) · 2024

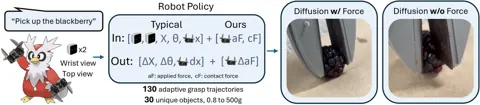
  • Figure from the paper “Just Add Force for Contact-Rich Robot Policies”

    Just Add Force for Contact-Rich Robot Policies

    William Xie, Stefan Caldararu, Nikolaus Correll

    arXiv (Cornell University) · 2024

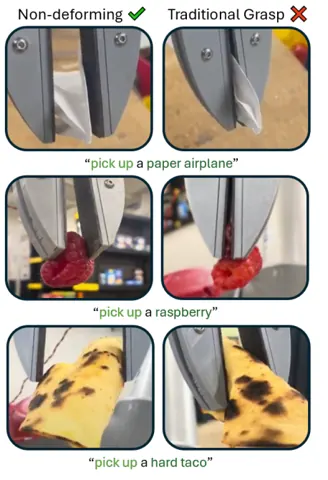
  • Figure from the paper “DeliGrasp: Inferring Object Properties with LLMs for Adaptive Grasp Policies”

    DeliGrasp: Inferring Object Properties with LLMs for Adaptive Grasp Policies

    William Xie, Valentini, Maria, Jensen Lavering, Nikolaus Correll

    arXiv (Cornell University) · 2024

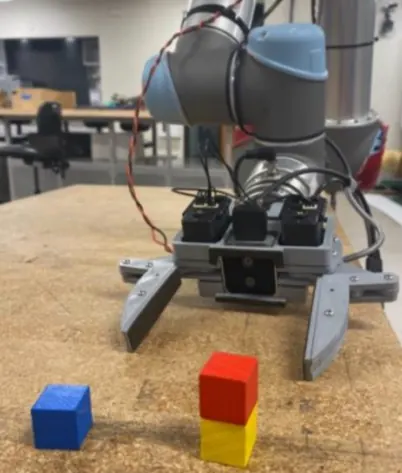
  • Figure from the paper “A versatile robotic hand with 3D perception, force sensing for autonomous manipulation”

    A versatile robotic hand with 3D perception, force sensing for autonomous manipulation

    Nikolaus Correll, Dylan Kriegman, Stephen Otto, James Watson

    arXiv (Cornell University) · 2024

  • First page of the paper “Software Engineering for Robotics: Future Research Directions; Report from the 2023 Workshop on Software Engineering for Robotics”

    Software Engineering for Robotics: Future Research Directions; Report from the 2023 Workshop on Software Engineering for Robotics

    Claire Le Goues, Sebastian Elbaum, Anthony S. David, Celik, Z. Berkay, Mauricio Castillo‐Effen, Nikolaus Correll, Pooyan Jamshidi, Morgan Quigley and 2 more

    arXiv (Cornell University) · 2024

2023 3 publications

  • A multifunctional soft robotic shape display with high-speed actuation, sensing, and control

    Brian K. Johnson, Mantas Naris, Vani Sundaram, Angella Volchko, Kevin Ly, Shane K. Mitchell, Eric Acome, Nicholas Kellaris and 4 more

    Nature Communications · 2023

  • Distributed Tactile Sensors for Palmar Surfaces of Prosthetic Hands

    Hoang Truong, Nikolaus Correll, Jacob L. Segil

    2023

  • Figure from the paper “Optimal decision making in robotic assembly and other trial-and-error tasks”

    Optimal decision making in robotic assembly and other trial-and-error tasks

    James Watson, Nikolaus Correll

    arXiv (Cornell University) · 2023

2022 4 publications

  • Toward smart composites: Small-scale, untethered prediction and control for soft sensor/actuator systems

    Sarah Aguasvivas Manzano, Vani Sundaram, Artemis Xu, Khoi Ly, Mark E. Rentschler, Robert F. Shepherd, Nikolaus Correll

    Journal of Composite Materials · 2022

  • Embedded Magnetic Sensing for Feedback Control of Soft HASEL Actuators

    Vani Sundaram, Khoi Ly, Brian K. Johnson, Mantas Naris, Maxwell P. Anderson, J. Sean Humbert, Nikolaus Correll, Mark E. Rentschler

    IEEE Transactions on Robotics · 2022

  • Electro-Hydraulic Rolling Soft Wheel: Design, Hybrid Dynamic Modeling, and Model Predictive Control

    Khoi Ly, Jatin V. Mayekar, Sarah Aguasvivas, Christoph Keplinger, Mark E. Rentschler, Nikolaus Correll

    IEEE Transactions on Robotics · 2022

  • Augmented reality for human–swarm interaction in a swarm-robotic chemistry simulation

    Sumeet Batra, John Klingner, Nikolaus Correll

    Artificial Life and Robotics · 2022

2021 3 publications

  • Interview with Nikolaus Correll: Robotic Materials

    Nikolaus Correll, Michaël Friedman, Karin Krauthausen

    2021

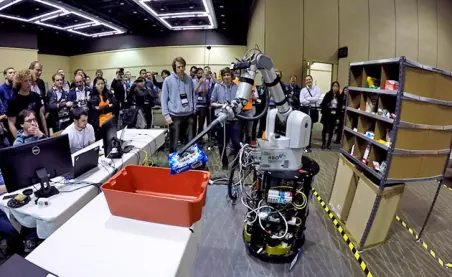
  • Figure from the paper “Mobile Manipulation Hackathon: Moving into Real World Applications”

    Mobile Manipulation Hackathon: Moving into Real World Applications

    Máximo A. Roa, Mehmet R. Doğar, Jordi Pagès, Carlos Vivas, Antonio Morales, Nikolaus Correll, Michael Görner, Jan Rosell and 3 more

    IEEE Robotics & Automation Magazine · 2021

  • Figure from the paper “High-bandwidth nonlinear control for soft actuators with recursive network models”

    High-bandwidth nonlinear control for soft actuators with recursive network models

    Sarah Aguasvivas Manzano, Patricia Xu, Khoi Ly, Robert F. Shepherd, Nikolaus Correll

    arXiv (Cornell University) · 2021

2020 5 publications

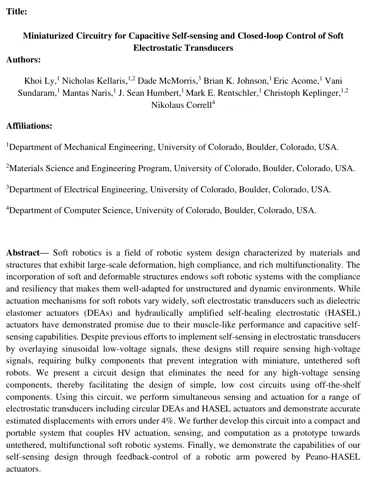
  • First page of the paper “Miniaturized Circuitry for Capacitive Self-Sensing and Closed-Loop Control of Soft Electrostatic Transducers”

    Miniaturized Circuitry for Capacitive Self-Sensing and Closed-Loop Control of Soft Electrostatic Transducers

    Khoi Ly, Nicholas Kellaris, Dade McMorris, Brian K. Johnson, Eric Acome, Vani Sundaram, Mantas Naris, J. Sean Humbert and 3 more

    Soft Robotics · 2020

  • First page of the paper “Miniaturized Circuitry for Capacitive Self-sensing and Closed-loop\n Control of Soft Electrostatic Transducers”

    Miniaturized Circuitry for Capacitive Self-sensing and Closed-loop\n Control of Soft Electrostatic Transducers

    Khoi Ly, Nicholas Kellaris, Dade McMorris, Brian K. Johnson, Eric Acome, Vani Sundaram, Mantas Naris, J. Sean Humbert and 3 more

    arXiv (Cornell University) · 2020

  • SIRONA: Sustainable Integration of Regenerative Outer-space Nature and Agriculture. Part 2 — Design Development and Projected Performance

    Heather Hava, Hanying Zhou, Chad Mehlenbeck, Abby King, Elizabeth M. Lombardi, Kyri Baker, Andy Kaufman, Nikolaus Correll

    Acta Astronautica · 2020

  • Robots and autonomous systems, SI DARS 2018

    Nikolaus Correll, Mac Schwager

    Robotics and Autonomous Systems · 2020

  • Identification and Control of a Nonlinear Soft Actuator and Sensor System

    Brian K. Johnson, Vani Sundaram, Mantas Naris, Eric Acome, Khoi Ly, Nikolaus Correll, Christoph Keplinger, J. Sean Humbert and 1 more

    IEEE Robotics and Automation Letters · 2020

2019 6 publications

  • Figure from the paper “Robots assembling machines: learning from the World Robot Summit 2018 Assembly Challenge”

    Robots assembling machines: learning from the World Robot Summit 2018 Assembly Challenge

    Felix von Drigalski, Christian Schlette, Martin Rudorfer, Nikolaus Correll, Joshua C. Triyonoputro, Weiwei Wan, Tokuo Tsuji, Tetsuyou Watanabe

    Advanced Robotics · 2019

  • Fault-tolerant Covariance Intersection for localizing robot swarms

    John Klingner, Nisar Ahmed, Nikolaus Correll

    Robotics and Autonomous Systems · 2019

  • SIRONA: Sustainable Integration of Regenerative Outer-space Nature and Agriculture. Part 1 -- Architecture and Technology

    Heather Hava, Larissa Zhou, Elizabeth M. Lombardi, Kaixin Cui, Heeyeon Joung, Sarah Aguasvivas Manzano, Abby King, Hayley Kinlaw and 3 more

    ThinkTech (Texas Tech University) · 2019

  • Materials that make robots smart

    Dana Hughes, Christoffer Heckman, Nikolaus Correll

    The International Journal of Robotics Research · 2019

  • Figure from the paper “Multi-modal prosthetic fingertip sensor with proximity, contact, and force localization capabilities”

    Multi-modal prosthetic fingertip sensor with proximity, contact, and force localization capabilities

    Jacob L. Segil, Radhen Patel, John Klingner, Richard F. Weir, Nikolaus Correll

    Advances in Mechanical Engineering · 2019

  • First page of the paper “Robotic Materials”

    Robotic Materials

    Nikolaus Correll, Ray H. Baughman, Richard M. Voyles, Lining Yao, Dan Inman

    arXiv (Cornell University) · 2019

2018 13 publications

  • Robotic materials for robot autonomy

    Nikolaus Correll

    Elsevier eBooks · 2018

  • List of contributors

    Nozomi Akashi, Iain A. Anderson, Yasemin Ozkan-Aydin, Daniel M. Baechle, Remmi Baker, Anna C. Balazs, Allan M. Brooks, Nikolaus Correll and 45 more

    Elsevier eBooks · 2018

  • Shape-Changing Materials Using Variable Stiffness and Distributed Control

    Michael McEvoy, Nikolaus Correll

    Soft Robotics · 2018

  • System Identification and Closed-Loop Control of a Hydraulically Amplified Self-Healing Electrostatic (HASEL) Actuator

    Cosima Schunk, Levi Pearson, Eric Acome, Timothy G. Morrissey, Nikolaus Correll, Christoph Keplinger, Mark E. Rentschler, J. Sean Humbert

    2018

  • Figure from the paper “From Natural to Artificial Camouflage: Components and Systems”

    From Natural to Artificial Camouflage: Components and Systems

    Yang Li, Nikolaus Correll

    arXiv (Cornell University) · 2018

  • Integrated proximity, contact and force sensing using elastomer-embedded commodity proximity sensors

    Radhen Patel, Rebecca Cox, Nikolaus Correll

    Autonomous Robots · 2018

  • Dynamic teams of robots as ad hoc distributed computers: reducing the complexity of multi-robot motion planning via subspace selection

    Michael Otte, Nikolaus Correll

    Autonomous Robots · 2018

  • Distributed camouflage for swarm robotics and smart materials

    Yang Li, John Klingner, Nikolaus Correll

    Autonomous Robots · 2018

  • A Robotic Skin for Collision Avoidance and Affective Touch Recognition

    Dana Hughes, JOHN LAMMIE, Nikolaus Correll

    IEEE Robotics and Automation Letters · 2018

  • Wireless Online Impact Source Localization on a Composite

    Sarah Aguasvivas Manzano, Dana Hughes, Nikolaus Correll

    Procedia Manufacturing · 2018

  • Manipulation Using the “Utah” Prosthetic Hand: The Role of Stiffness in Manipulation

    Radhen Patel, Jacob L. Segil, Nikolaus Correll

    Communications in computer and information science · 2018

  • Improving Grasp Performance Using In-Hand Proximity and Contact Sensing

    Radhen Patel, Rebeca Curtis, Branden Romero, Nikolaus Correll

    Communications in computer and information science · 2018

  • Distributed Convolutional Neural Networks for Human Activity Recognition in Wearable Robotics

    Dana Hughes, Nikolaus Correll

    Springer proceedings in advanced robotics · 2018

2017 12 publications

  • Will robots be bodies with brains or brains with bodies?

    Yiğit Mengüç, Nikolaus Correll, Rebecca K. Kramer, Jamie Paik

    Science Robotics · 2017

  • Wireless Robotic Materials

    Nikolaus Correll, Prabal Dutta, Richard Han, Kristofer S. J. Pister

    2017

  • Figure from the paper “New Directions: Wireless Robotic Materials”

    New Directions: Wireless Robotic Materials

    Nikolaus Correll, Prabal Dutta, Richard Han, Kristofer S. J. Pister

    arXiv (Cornell University) · 2017

  • Fast Sample-Based Planning for Dynamic Systems by Zero-Control Linearization-Based Steering

    Timothy M. Caldwell, Nikolaus Correll

    Springer proceedings in advanced robotics · 2017

  • Soft Robotics: Review of Fluid‐Driven Intrinsically Soft Devices; Manufacturing, Sensing, Control, and Applications in Human‐Robot Interaction

    Panagiotis Polygerinos, Nikolaus Correll, Stephen A. Morin, Bobak Mosadegh, Çağdaş D. Önal, Kirstin Petersen, Matteo Cianchetti, Michael T. Tolley and 1 more
    Advanced Engineering Materials · 2017

  • Recognizing social touch gestures using recurrent and convolutional neural networks

    Dana Hughes, Alon Krauthammer, Nikolaus Correll

    2017

  • Functionalized textiles for interactive soft robotics

    Nicholas Farrow, Lauren McIntire, Nikolaus Correll

    2017

  • To really help US workers, we should invest in robots

    Nikolaus Correll

    2017

  • Intelligent RF-Based Gesture Input Devices Implemented Using e-Textiles

    Dana Hughes, Halley Profita, Sarah Radzihovsky, Nikolaus Correll

    Sensors · 2017

  • Textile-Based Wearables

    Michael Lightner, Shaun K. Kane, Nikolaus Correll, Halley Profita

    2017

  • Merging Local and Global 3D Perception using Contact Sensing.

    Rebecca Cox, Nikolaus Correll

    National Conference on Artificial Intelligence · 2017

  • Improving Grasp Performance Using In-Hand Proximity and Dynamic Tactile Sensing

    Radhen Patel, Jorge Cañardo Alastuey, Nikolaus Correll

    Springer proceedings in advanced robotics · 2017

2016 12 publications

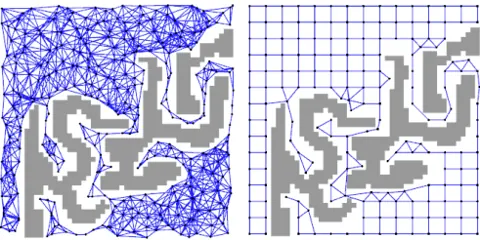
  • Figure from the paper “Sparser Sparse Roadmaps”

    Sparser Sparse Roadmaps

    David Coleman, Nikolaus Correll

    arXiv (Cornell University) · 2016

  • Analysis and Observations From the First Amazon Picking Challenge

    Nikolaus Correll, Kostas E. Bekris, Dmitry Berenson, Oliver Brock, Albert Causo, Kris Hauser, Kei Okada, Alberto Rodríguez and 2 more
    IEEE Transactions on Automation Science and Engineering · 2016

  • Figure from the paper “Consensus or Deadlock? Consequences of Simple Behavioral Rules for Coordination in Group Decisions”

    Consensus or Deadlock? Consequences of Simple Behavioral Rules for Coordination in Group Decisions

    Helen F. McCreery, Nikolaus Correll, Michael D. Breed, Samuel M. Flaxman

    PLoS ONE · 2016

  • Figure from the paper “Integrated force and distance sensing using elastomer-embedded commodity proximity sensors”

    Integrated force and distance sensing using elastomer-embedded commodity proximity sensors

    Radhen Patel, Nikolaus Correll

    2016

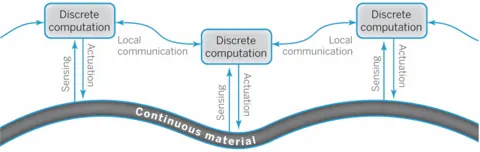
  • Figure from the paper “Distributed Machine Learning in Materials that Couple Sensing, Actuation, Computation and Communication”

    Distributed Machine Learning in Materials that Couple Sensing, Actuation, Computation and Communication

    Dana Hughes, Nikolaus Correll

    arXiv (Cornell University) · 2016

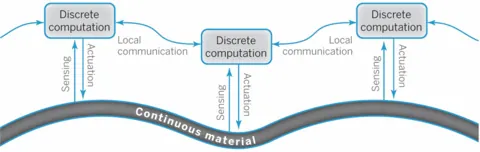
  • Figure from the paper “Distributed Machine Learning in Materials that Couple Sensing,\n Actuation, Computation and Communication”

    Distributed Machine Learning in Materials that Couple Sensing,\n Actuation, Computation and Communication

    Dana Hughes, Nikolaus Correll

    arXiv (Cornell University) · 2016

  • Figure from the paper “Morphological and Embedded Computation in a Self-contained Soft Robotic Hand”

    Morphological and Embedded Computation in a Self-contained Soft Robotic Hand

    Nicholas Farrow, Yang Li, Nikolaus Correll

    arXiv (Cornell University) · 2016

  • Modeling multi-robot task allocation with limited information as global game

    Anshul Kanakia, Behrouz Touri, Nikolaus Correll

    Swarm Intelligence · 2016

  • Figure from the paper “Lessons from the Amazon Picking Challenge.”

    Lessons from the Amazon Picking Challenge.

    Nikolaus Correll, Kostas E. Bekris, Dmitry Berenson, Oliver Brock, Albert Causo, Kris Hauser, Kei Okada, Alberto Rodríguez and 2 more
    arXiv (Cornell University) · 2016

  • Simulating Chemical Reactions Using a Swarm of Miniature Robots

    Audrey Randall, John Klingner, Nikolaus Correll

    Lecture notes in computer science · 2016

  • Distributed Inverse Kinematics for Shape-changing Robotic Materials

    Michael McEvoy, Nikolaus Correll

    Procedia Technology · 2016

  • A Response Threshold Sigmoid Function Model for Swarm Robot Collaboration

    Anshul Kanakia, John Klingner, Nikolaus Correll

    Springer tracts in advanced robotics · 2016

2015 11 publications

  • Shape Change Through Programmable Stiffness

    Michael McEvoy, Nikolaus Correll

    Springer tracts in advanced robotics · 2015

  • Robotic Manipulation for Identification of Flexible Objects

    Timothy M. Caldwell, David Coleman, Nikolaus Correll

    Springer tracts in advanced robotics · 2015

  • Precise Assembly of 3D Truss Structures Using EKF-Based Error Prediction and Correction

    Erik Komendera, Nikolaus Correll

    Springer tracts in advanced robotics · 2015

  • Detecting and Identifying Tactile Gestures using Deep Autoencoders, Geometric Moments and Gesture Level Features

    Dana Hughes, Nicholas Farrow, Halley Profita, Nikolaus Correll

    2015

  • Precise assembly of 3D truss structures using MLE-based error prediction and correction

    Erik Komendera, Nikolaus Correll

    The International Journal of Robotics Research · 2015

  • Texture recognition and localization in amorphous robotic skin

    Dana Hughes, Nikolaus Correll

    Bioinspiration & Biomimetics · 2015

  • Distributed Spatiotemporal Gesture Recognition in Sensor Arrays

    Homa Hosseinmardi, Akshay Mysore, Nicholas Farrow, Nikolaus Correll, Richard Han

    ACM Transactions on Autonomous and Adaptive Systems · 2015

  • A soft pneumatic actuator that can sense grasp and touch

    Nicholas Farrow, Nikolaus Correll

    2015

  • Materials that couple sensing, actuation, computation, and communication

    Michael McEvoy, Nikolaus Correll

    Science · 2015

  • Flutter

    Halley Profita, Nicholas Farrow, Nikolaus Correll

    2015

  • Probabilistic Modeling of Swarming Systems

    Nikolaus Correll, Heiko Hamann

    2015

2014 21 publications

  • Figure from the paper “Simultaneous Localization, Mapping, and Manipulation for Unsupervised Object Discovery”

    Simultaneous Localization, Mapping, and Manipulation for Unsupervised Object Discovery

    Lu Ma, Mahsa Ghafarianzadeh, Dave Coleman, Nikolaus Correll, Gabe Sibley

    arXiv (Cornell University) · 2014

  • Figure from the paper “Experience-Based Planning with Sparse Roadmap Spanners”

    Experience-Based Planning with Sparse Roadmap Spanners

    David Coleman, Ioan A. Şucan, Mark Moll, Kei Okada, Nikolaus Correll

    arXiv (Cornell University) · 2014

  • SwitchBack

    Dana Hughes, Halley Profita, Nikolaus Correll

    2014

  • Figure from the paper “Optimal parameter identification for discrete mechanical systems with application to flexible object manipulation”

    Optimal parameter identification for discrete mechanical systems with application to flexible object manipulation

    Timothy M. Caldwell, Dave Coleman, Nikolaus Correll

    2014

  • A stick-slip omnidirectional powertrain for low-cost swarm robotics: Mechanism, calibration, and control

    John Klingner, Anshul Kanakia, Nicholas Farrow, Dustin Reishus, Nikolaus Correll

    2014

  • Endo/Exo Making Art And Music With Distributed Computing

    Jiffer Harriman, Michael Theodore, Nikolaus Correll, Hunter Ewen

    Zenodo (CERN European Organization for Nuclear Research) · 2014

  • Crowdfunding of science leads to innovation and better public engagement

    Nikolaus Correll

    2014

  • First page of the paper “C-FOREST: Parallel Shortest-Path Planning with Super Linear Speedup”

    C-FOREST: Parallel Shortest-Path Planning with Super Linear Speedup

    Michael Otte, Nikolaus Correll

    Proceedings of the International Conference on Automated Planning and Scheduling · 2014

  • Miniature six-channel range and bearing system: Algorithm, analysis and experimental validation

    Nicholas Farrow, John Klingner, Dustin Reishus, Nikolaus Correll

    2014

  • A soft, amorphous skin that can sense and localize textures

    Dana Hughes, Nikolaus Correll

    2014

  • Truss Assembly and Welding by Intelligent Precision Jigging Robots

    Erik Komendera, John T. Dorsey, William R. Doggett, Nikolaus Correll

    NASA STI Repository (National Aeronautics and Space Administration) · 2014

  • Assembly path planning for stable robotic construction

    Michael McEvoy, Erik Komendera, Nikolaus Correll

    2014

  • Abstracting perception and manipulation in end-user robot programming using Sikuli

    Michael Kasper, Nikolaus Correll, Tom Yeh

    2014

  • Thermoplastic variable stiffness composites with embedded, networked sensing, actuation, and control

    Michael McEvoy, Nikolaus Correll

    Journal of Composite Materials · 2014

  • Gesture based distributed user interaction system for a reconfigurable self-organizing smart wall

    Nicholas Farrow, Naren Sivagnanadasan, Nikolaus Correll

    2014

  • Figure from the paper “Optimal Parameter Identification for Discrete Mechanical Systems with\n Application to Flexible Object Manipulation”

    Optimal Parameter Identification for Discrete Mechanical Systems with\n Application to Flexible Object Manipulation

    Timothy M. Caldwell, Dave Coleman, Nikolaus Correll

    arXiv (Cornell University) · 2014

  • Towards Real-Time Trinocular Visual Odometry

    Jae Heon Jeong, Nikolaus Correll

    Applied Mechanics and Materials · 2014

  • SikuliBot

    Jeeeun Kim, Mike Kasper, Tom Yeh, Nikolaus Correll

    2014

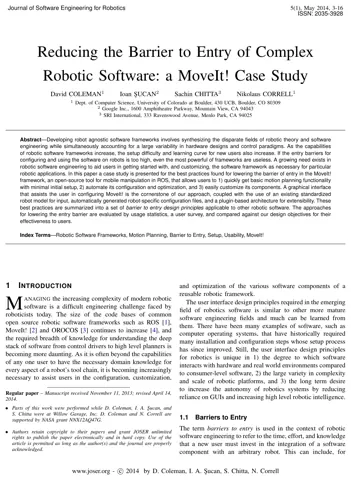
  • First page of the paper “Reducing the Barrier to Entry of Complex Robotic Software: a MoveIt! Case Study”

    Reducing the Barrier to Entry of Complex Robotic Software: a MoveIt! Case Study

    David Coleman, Ioan A. Şucan, Sachin Chitta, Nikolaus Correll

    Aisberg (University of Bergamo) · 2014

  • Object Transportation by Granular Convection Using Swarm Robots

    Ken Sugawara, Nikolaus Correll, Dustin Reishus

    Springer tracts in advanced robotics · 2014

  • A One-Hour Curriculum to Engage Middle School Students in Robotics and Computer Science Using Cubelets

    Nikolaus Correll, Chris Wailes, Scott Slaby

    Springer tracts in advanced robotics · 2014

2013 10 publications

  • Space exploration can drive the next agricultural revolution

    Nikolaus Correll

    2013

  • Navigation with foraging

    Michael Otte, Nikolaus Correll, Emilio Frazzoli

    2013

  • Soft Autonomous Materials—Using Active Elasticity and Embedded Distributed Computation

    Nikolaus Correll, Çağdaş D. Önal, Haiyi Liang, Erik Schoenfeld, Daniela Rus

    Springer tracts in advanced robotics · 2013

  • Any-Com Multi-robot Path-Planning with Dynamic Teams: Multi-robot Coordination under Communication Constraints

    Michael Otte, Nikolaus Correll

    Springer tracts in advanced robotics · 2013

  • Self-Organized Robotic Systems

    Grégory Mermoud, Amanda Prorok, Löıc Matthey, Christopher Cianci, Nikolaus Correll, Alcherio Martinoli

    Pan Stanford eBooks · 2013

  • Architectures and Control of Networked Robotic Systems

    Nikolaus Correll, Daniela Rus

    2013

  • Precise truss assembly using commodity parts and low precision welding

    Erik Komendera, Dustin Reishus, Nikolaus Correll

    2013

  • HoneyComb

    Nikolaus Correll, Nicholas Farrow, Shang Ma

    2013

  • C-FOREST: Parallel Shortest Path Planning With Superlinear Speedup

    Michaël Otte, Nikolaus Correll

    IEEE Transactions on Robotics · 2013

  • Trinocular visual odometry for divergent views with minimal overlap

    Jaeheon Jeong, J. Mulligan, Nikolaus Correll

    2013

2012 9 publications

  • Establishing Multi-cast Groups in Computational Robotic Materials

    Shang Ma, Homa Hosseinmardi, Nicholas Farrow, Richard Han, Nikolaus Correll

    2012

  • A One-Year Introductory Robotics Curriculum for Computer Science Upperclassmen

    Nikolaus Correll, Rowan Wing, David Coleman

    IEEE Transactions on Education · 2012

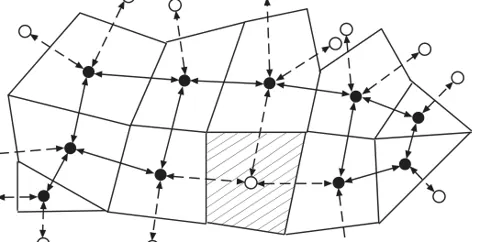
  • Organizing the Aggregate

    Jacob Beal, Stefan Dulman, Kyle Usbeck, Mirko Viroli, Nikolaus Correll

    IGI Global eBooks · 2012

  • Figure from the paper “An Efficient and Versatile Means for Assembling and Manufacturing Systems in Space”

    An Efficient and Versatile Means for Assembling and Manufacturing Systems in Space

    John T. Dorsey, William R. Doggett, Robert A. Hafley, Erik Komendera, Nikolaus Correll, Bruce King

    2012

  • Figure from the paper “Distributed Autonomous Robotic Systems: The 10th International Symposium”

    Distributed Autonomous Robotic Systems: The 10th International Symposium

    Alcherio Martinoli, Francesco Mondada, Nikolaus Correll, Grgory Mermoud, Magnus Egerstedt, M. Ani Hsieh, Lynne E. Parker, Kasper Sty

    2012

  • Distributed Autonomous Robotic Systems

    Alcherio Martinoli, Francesco Mondada, Nikolaus Correll, Grégory Mermoud, Magnus Egerstedt, M. Ani Hsieh, Lynne E. Parker, Kasper Støy

    Springer tracts in advanced robotics · 2012

  • Any-Com Multi-robot Path-Planning: Maximizing Collaboration for Variable Bandwidth

    Michael Otte, Nikolaus Correll

    Springer tracts in advanced robotics · 2012

  • First page of the paper “Organizing the Aggregate: Languages for Spatial Computing”

    Organizing the Aggregate: Languages for Spatial Computing

    Jacob Beal, Stefan Dulman, Kyle Usbeck, Mirko Viroli, Nikolaus Correll

    arXiv (Cornell University) · 2012

  • Bloom Filter-Based Ad Hoc Multicast Communication in Cyber-Physical Systems and Computational Materials

    Homa Hosseinmardi, Nikolaus Correll, Richard Han

    Lecture notes in computer science · 2012

2011 6 publications

  • Self-assembly of modular robots from finite number of modules using graph grammars

    Vijeth Rai, Anne van Rossum, Nikolaus Correll

    2011 IEEE/RSJ International Conference on Intelligent Robots and Systems · 2011

  • Decentralized self-repair to maintain connectivity and coverage in networked multi-robot systems

    Anna Derbakova, Nikolaus Correll, Daniela Rus

    2011

  • First page of the paper “Modeling and designing self-organized aggregation in a swarm of miniature robots”

    Modeling and designing self-organized aggregation in a swarm of miniature robots

    Nikolaus Correll, Alcherio Martinoli

    The International Journal of Robotics Research · 2011

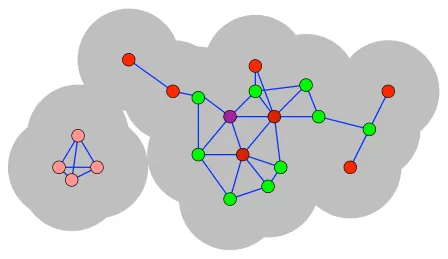
  • Multi-level spatial modeling for stochastic distributed robotic systems

    Amanda Prorok, Nikolaus Correll, Alcherio Martinoli

    The International Journal of Robotics Research · 2011

  • First page of the paper “Path Planning with Forests of Random Trees: Parallelization with Super Linear Speedup ; CU-CS-1079-11”

    Path Planning with Forests of Random Trees: Parallelization with Super Linear Speedup ; CU-CS-1079-11

    Michael Otte, Nikolaus Correll

    CU Scholar (University of Colorado Boulder) · 2011

  • Figure from the paper “Assembly by Intelligent Scaffolding ; CU-CS-1080-11”

    Assembly by Intelligent Scaffolding ; CU-CS-1080-11

    Erik Komendera, Dustin Reishus, Nikolaus Correll

    CU Scholar (University of Colorado Boulder) · 2011

2010 4 publications

  • Object Interaction Language (OIL): An intent-based language for programming self-organized sensor/actuator networks

    Dwight Sutton, Phil Klein, Michael Otte, Nikolaus Correll

    2010

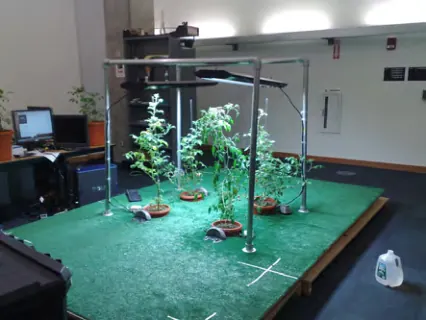
  • Indoor robot gardening: design and implementation

    Nikolaus Correll, Nikos Aréchiga, Adrienne Bolger, M. Bollini, Ben Charrow, Adam Clayton, Felipe Dominguez, Kenneth Donahue and 10 more
    Intelligent Service Robotics · 2010

  • From swarm robotics to smart materials

    Nikolaus Correll, Roderich Groß

    Neural Computing and Applications · 2010

  • Multiple Object 3D-Mapping using a Physics Simulator ; CU-CS-1069-10

    Neeti Wagle, Nikolaus Correll

    CU Scholar (University of Colorado Boulder) · 2010

2009 4 publications

  • Figure from the paper “Building a distributed robot garden”
    Building a distributed robot garden

    Nikolaus Correll, Nikos Aréchiga, Adrienne Bolger, M. Bollini, Ben Charrow, Adam Clayton, Felipe Dominguez, Kenneth Donahue and 10 more

    2009

  • Ad-hoc wireless network coverage with networked robots that cannot localize

    Nikolaus Correll, Jonathan Bachrach, D. Vickery, Daniela Rus

    2009

  • Multirobot inspection of industrial machinery

    Nikolaus Correll, Alcherio Martinoli

    IEEE Robotics & Automation Magazine · 2009

  • Figure from the paper “Behavior Modes for Randomized Robotic Coverage”

    Behavior Modes for Randomized Robotic Coverage

    Jacob Beal, Nikolaus Correll, Leonardo Urbina, Jonathan Bachrach

    2009

2008 10 publications

  • Figure from the paper “Collaborative coverage using a swarm of networked miniature robots”

    Collaborative coverage using a swarm of networked miniature robots

    Samuel Rutishauser, Nikolaus Correll, Alcherio Martinoli

    Robotics and Autonomous Systems · 2008

  • PCP

    Hari Balakrishnan, Nikolaus Correll, Jakob Erikkson, Sejoon Lim, Samuel Madden, Daniela Rus

    2008

  • Cells and Robots: Modeling and Control of Large-Size Agent Populations (Dejan L.J. Milutinovic and P. Lima; 2007) [Book Review]

    Nikolaus Correll

    IEEE Control Systems · 2008

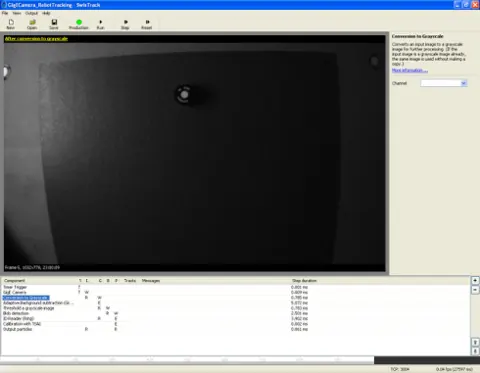
  • Figure from the paper “SwisTrack - A Flexible Open Source Tracking Software for Multi-Agent Systems”

    SwisTrack - A Flexible Open Source Tracking Software for Multi-Agent Systems

    Thomas Lochmatter, Pierre Roduit, Chris Cianci, Nikolaus Correll, Jacques Jacot, Alcherio Martinoli

    2008

  • Social Control of Herd Animals by Integration of Artificially Controlled Congeners

    Nikolaus Correll, Mac Schwager, Daniela Rus

    Lecture notes in computer science · 2008

  • Parameter estimation and optimal control of swarm-robotic systems: A case study in distributed task allocation

    Nikolaus Correll

    2008

  • Distributed boundary coverage with a team of networked miniature robots using a robust market-based algorithm

    Patrick Amstutz, Nikolaus Correll, Alcherio Martinoli

    Annals of Mathematics and Artificial Intelligence · 2008

  • Comparing Coordination Schemes for Miniature Robotic Swarms: A Case Study in Boundary Coverage of Regular Structures

    Nikolaus Correll, Samuel Rutishauser, Alcherio Martinoli

    Springer tracts in advanced robotics · 2008

  • Figure from the paper “Modeling and Optimization of a Swarm-Intelligent Inspection System”

    Modeling and Optimization of a Swarm-Intelligent Inspection System

    Nikolaus Correll, Alcherio Martinoli

    2008

  • Demo Abstract: PCP: The Personal Commute Portal

    Hari Balakrishnan, Nikolaus Correll, Jakob Erikkson, Sejoon Lim, Samuel Madden, Daniela Rus

    2008

2007 5 publications

  • First page of the paper “Social Integration of Robots into Groups of Cockroaches to Control Self-Organized Choices”

    Social Integration of Robots into Groups of Cockroaches to Control Self-Organized Choices

    José Halloy, Grégory Sempo, Gilles Caprari, Colette Rivault, Masoud Asadpour, Florin Tache, Imen Saïd, V. Durier and 8 more

    Science · 2007

  • First page of the paper “System Identification of Self-Organizing Robotic Swarms”

    System Identification of Self-Organizing Robotic Swarms

    Nikolaus Correll, Alcherio Martinoli

    2007

  • Figure from the paper “Robust Distributed Coverage using a Swarm of Miniature Robots”

    Robust Distributed Coverage using a Swarm of Miniature Robots

    Nikolaus Correll, Alcherio Martinoli

    Proceedings - IEEE International Conference on Robotics and Automation/Proceedings · 2007

  • Figure from the paper “Modeling Self-Organized Aggregation in a Swarm of Miniature Robots”

    Modeling Self-Organized Aggregation in a Swarm of Miniature Robots

    Nikolaus Correll, Alcherio Martinoli

    Infoscience (Ecole Polytechnique Fédérale de Lausanne) · 2007

  • Figure from the paper “A Challenging Application in Swarm Robotics: The Autonomous Inspection of Complex Engineered Structures”

    A Challenging Application in Swarm Robotics: The Autonomous Inspection of Complex Engineered Structures

    Nikolaus Correll, Alcherio Martinoli

    2007

2006 5 publications

  • Figure from the paper “SwisTrack: A Tracking Tool for Multi-Unit Robotic and Biological Systems”

    SwisTrack: A Tracking Tool for Multi-Unit Robotic and Biological Systems

    Nikolaus Correll, Grégory Sempo, Y.L. de Meneses, José Halloy, Jean‐Louis Deneubourg, Alcherio Martinoli

    2006

  • Figure from the paper “Modeling and Analysis of Beaconless and Beacon-Based Policies for a Swarm-Intelligent Inspection System”

    Modeling and Analysis of Beaconless and Beacon-Based Policies for a Swarm-Intelligent Inspection System

    Nikolaus Correll, Alcherio Martinoli

    2006

  • Figure from the paper “TOWARDS OPTIMAL CONTROL OF SELF-ORGANIZED ROBOTIC INSPECTION SYSTEMS”

    TOWARDS OPTIMAL CONTROL OF SELF-ORGANIZED ROBOTIC INSPECTION SYSTEMS

    Nikolaus Correll, Alcherio Martinoli

    IFAC Proceedings Volumes · 2006

  • Figure from the paper “Self-Organized Embedded Sensor/Actuator Networks for ""Smart"" Turbines”

    Self-Organized Embedded Sensor/Actuator Networks for ""Smart"" Turbines

    Nikolaus Correll, Christopher M. Cianci, Xavier Raemy, Alcherio Martinoli

    Infoscience (Ecole Polytechnique Fédérale de Lausanne) · 2006

  • Figure from the paper “Collective Inspection of Regular Structures using a Swarm of Miniature Robots”

    Collective Inspection of Regular Structures using a Swarm of Miniature Robots

    Nikolaus Correll, Alcherio Martinoli

    Springer tracts in advanced robotics · 2006

2002 1 publication

  • First page of the paper “6-DOF Visual Servoing Using the Lie Group of Affine Transformations”

    6-DOF Visual Servoing Using the Lie Group of Affine Transformations

    Nikolaus Correll

    Lund University Publications Student Papers (Lund University) · 2002

  • College of Engineering
  • Aerospace and Mechanical Engineering

Correll Laboratory

Notre Dame, IN 46556 USA ncorrell@nd.edu

  • Search
  • News
  • Events
  • Visit
  • Mobile App
  • Accessibility
  • Facebook
  • X/Twitter
  • Instagram
  • YouTube
  • LinkedIn

© 2026 University of Notre Dame

  • Home
  • Publications
  • People
  • Teaching
  • Art